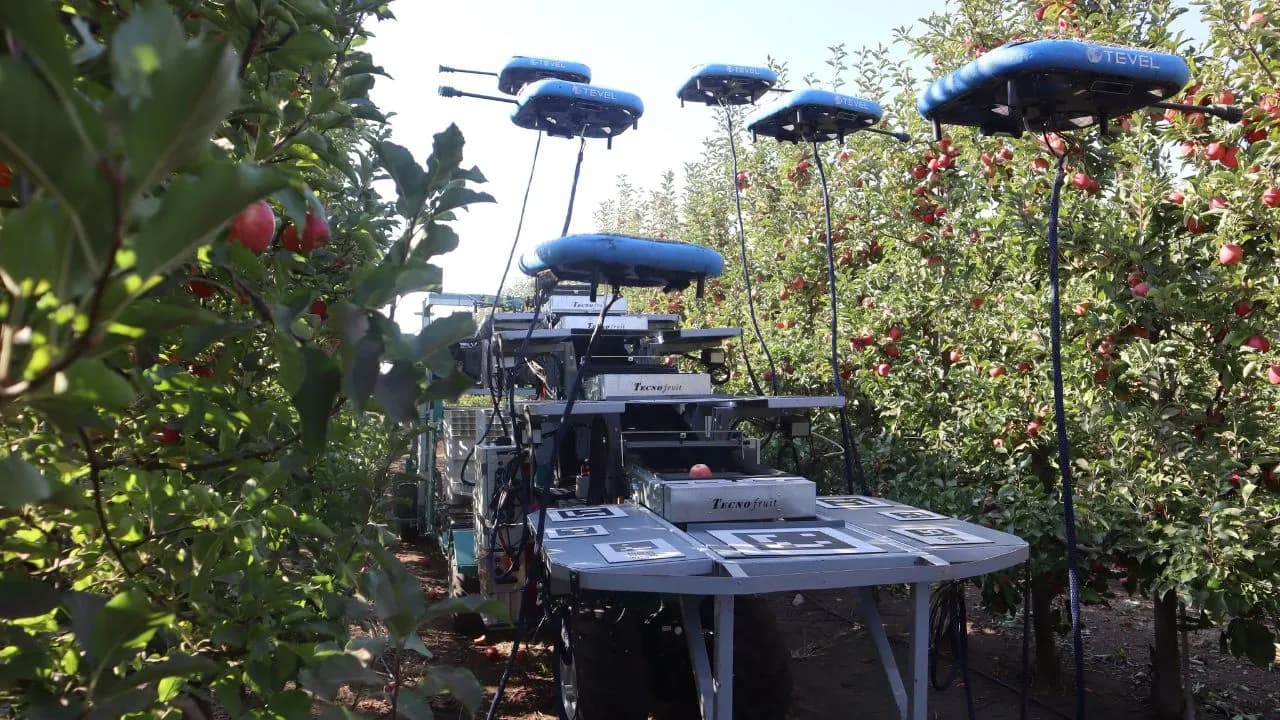
An orchard-harvesting robot system consisting of light flying robots that physically move through tree foliage and use a mechanical claw to pick fruit. It uses computer vision to classify fruit by attributes such as size and ripeness, balances forces from foliage and fruit, and records per-fruit weight, size, color, disease detection, timestamp, and geolocation.
The full profile is free
Create a free account to see every specification, classification, autonomy, crops, regions, data practices, pricing model, plus similar products. No card required.
Every listing is factual, neutral, and compiled from publicly available sources, never sponsored. Logos are used for identification only and remain the property of their respective owners. How the Atlas works.